FAULT ANALYSIS
A drone failure, traced across system boundaries
A personal field account from August 2012 near Crupet.
An unexpected failure
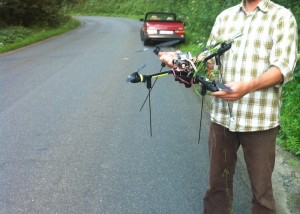
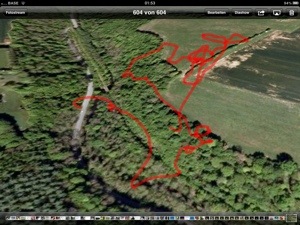
In August 2012 I was flying a folding multirotor with a modified Canon camera near Crupet. Control was lost and the aircraft had to be recovered. A telemetry signal and warning beeper helped locate it. The experience became a practical investigation of the whole system.
The misleading symptom
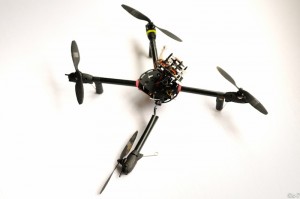
My published account describes failed vibration dampers and a sensor module left hanging freely. Barometric altitude holding and lateral control did not behave in the same way. Looking only at the flight-control software would have missed a mechanical problem with consequences for the sensor inputs.
Why I keep the story
It is a useful reminder to examine interfaces between mechanics, sensors, software and the physical environment. A plausible explanation is a starting point, not the end of diagnosis.
Original account: UAS-Model recovered after loss of control and subsequent crash, published on 9 August 2012. It records the flight, recovery and my analysis of the failed mounts.